Experience Projects
20251 YEAR
Delft, Netherlands

Treasurer of the executive board

K.S.V. Sanctus Virgilius

  • Fulltime function as one of the ten board members of the largest student association in Delft.
  • Oversaw around 2000 members and dealt with over 40 committees.
  • Operated bar and restaurant with an annual turnover of €2 million.
  • Managed ten employees.
  • Responsible for the financial policy, monitoring cash flows, budget distribution and the annual accounts.
Jul 20211 month
Dubai, UAE

Intern - systems enhancement and innovation

DP World

  • Interned at the Systems enhancement & Innovations department at DP World.
  • Through shadowing an employee, I was able to attend meetings, visit workshops, test prototypes as well as do research into commonly used robotic systems and hardware.
  • Towards the end I produced a comprehensive research report and was able to ask relevant questions and pitch appropriate ideas.
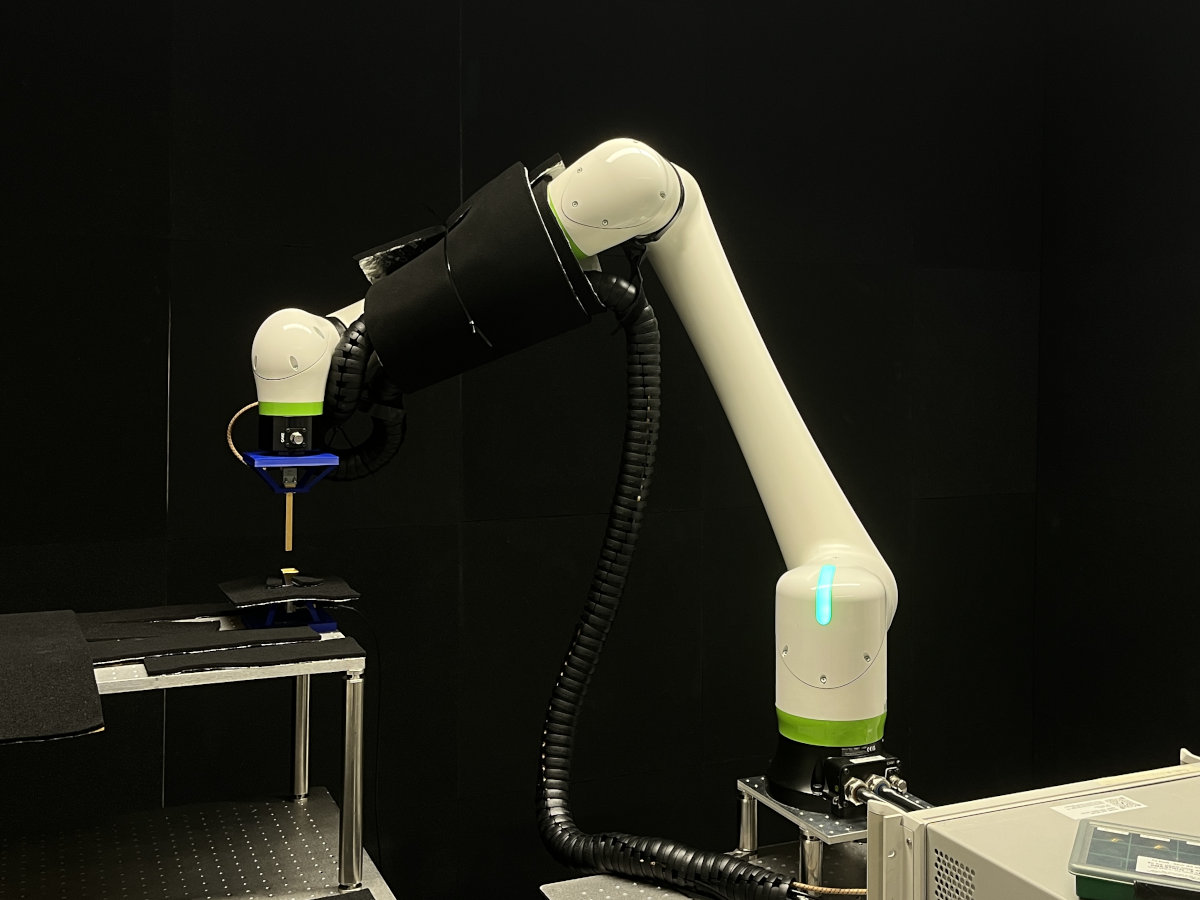
Robotic arm used for antenna measurements

Automated antenna radiation measurements

  • TU Delft
  • Bachelor Graduation Project
  • Performed high frequency antenna radiation measurements using a 6-axis robotic arm
  • Characterised time-domain antenna responses by applying inverse Fourier transforms on matrices of com- plex S-parameters.
  • Displayed live visualisation and results through a user interface
  • Analysed the repeatability of the measurements: within 0.8 dB and 30° phase
  • Quantified phase offset due to individual robotic arm joints: max 20°
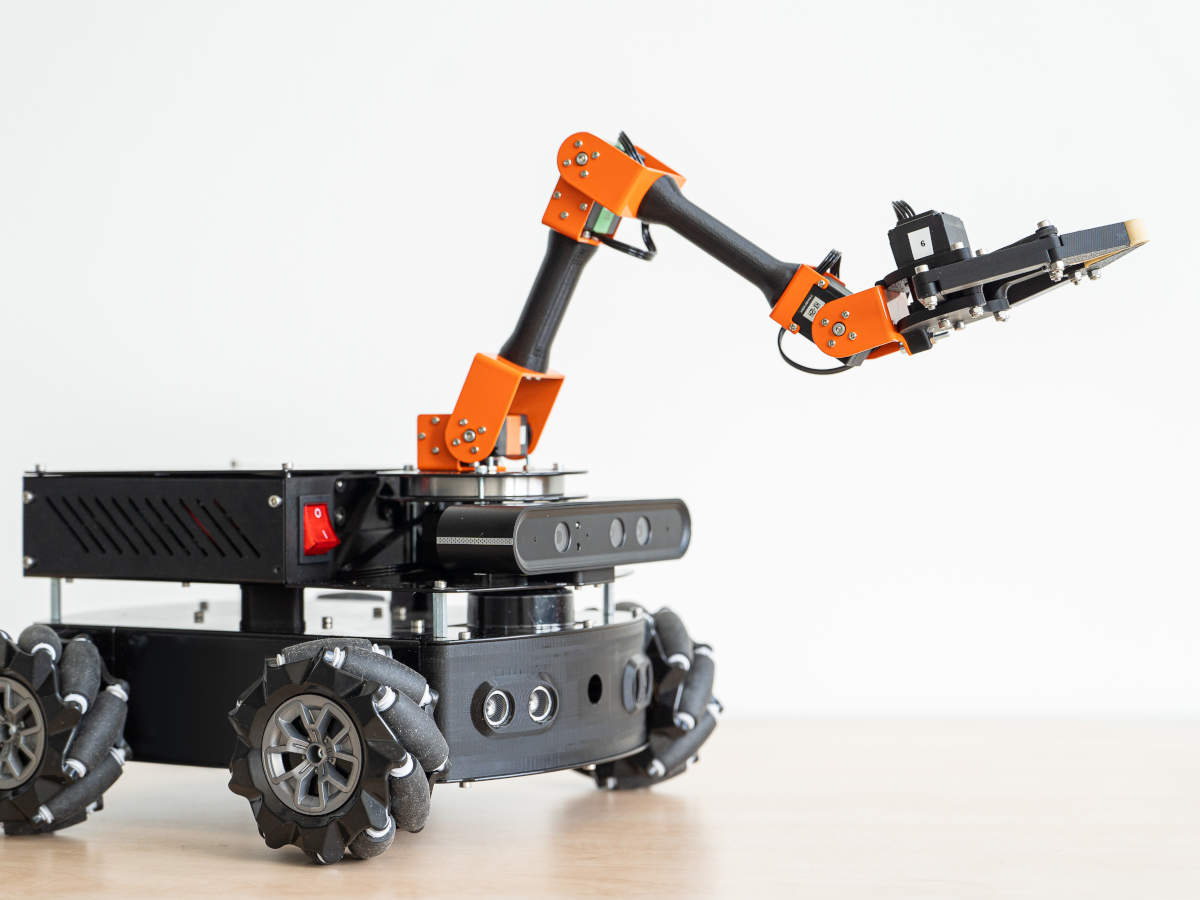
Mirte Master robot

Autonomous handling and navigation

  • TU Delft
  • Honours Project
  • Developed a scalable solution for autonomous handling of contaminated medical packaging sheets for recycling
  • Designed a hierarchical control architecture in ROS FlexBE, using finite state machines for high-level decision-making and local planning for obstacle avoidance
  • Implemented Adaptive Monte Carlo Localization (AMCL) SLAM algorithms for autonomous navigation in dynamic environments
  • Fused LiDAR and ultrasonic sensor data with a control system using particle filters and weighted averages to facilitate close-range positioning, achieving ±2 cm accuracy
Image: MIRTE

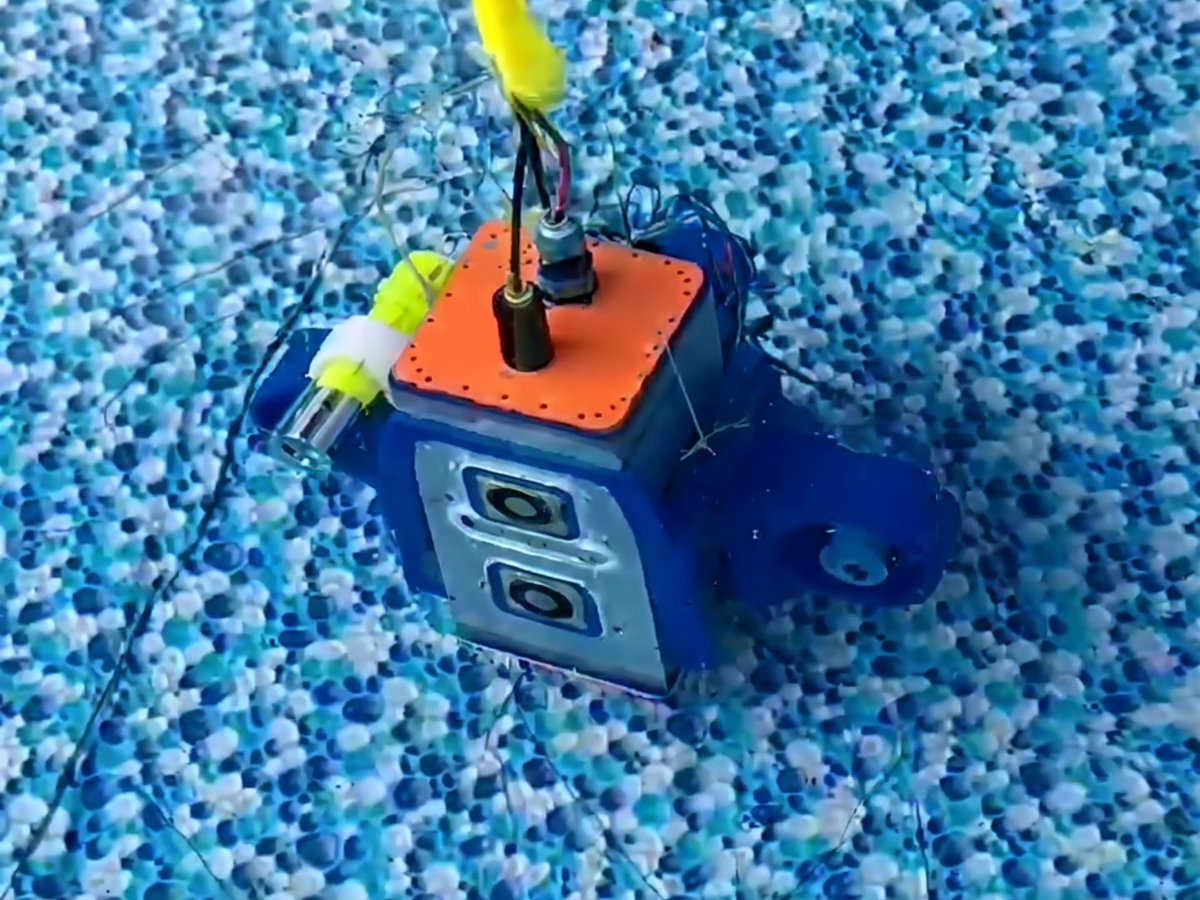
Underwater inspection robot

  • TU Delft
  • Robotics Minor Programme
  • Designed and built a proof of concept underwater robot for use in inspection of offshore infrastructure
  • Engineered the power distribution system, sensory systems and electromegnet control systems on a custom PCB
  • Incorporated fail-safe sensors and safety mechanisms to minimise water damage

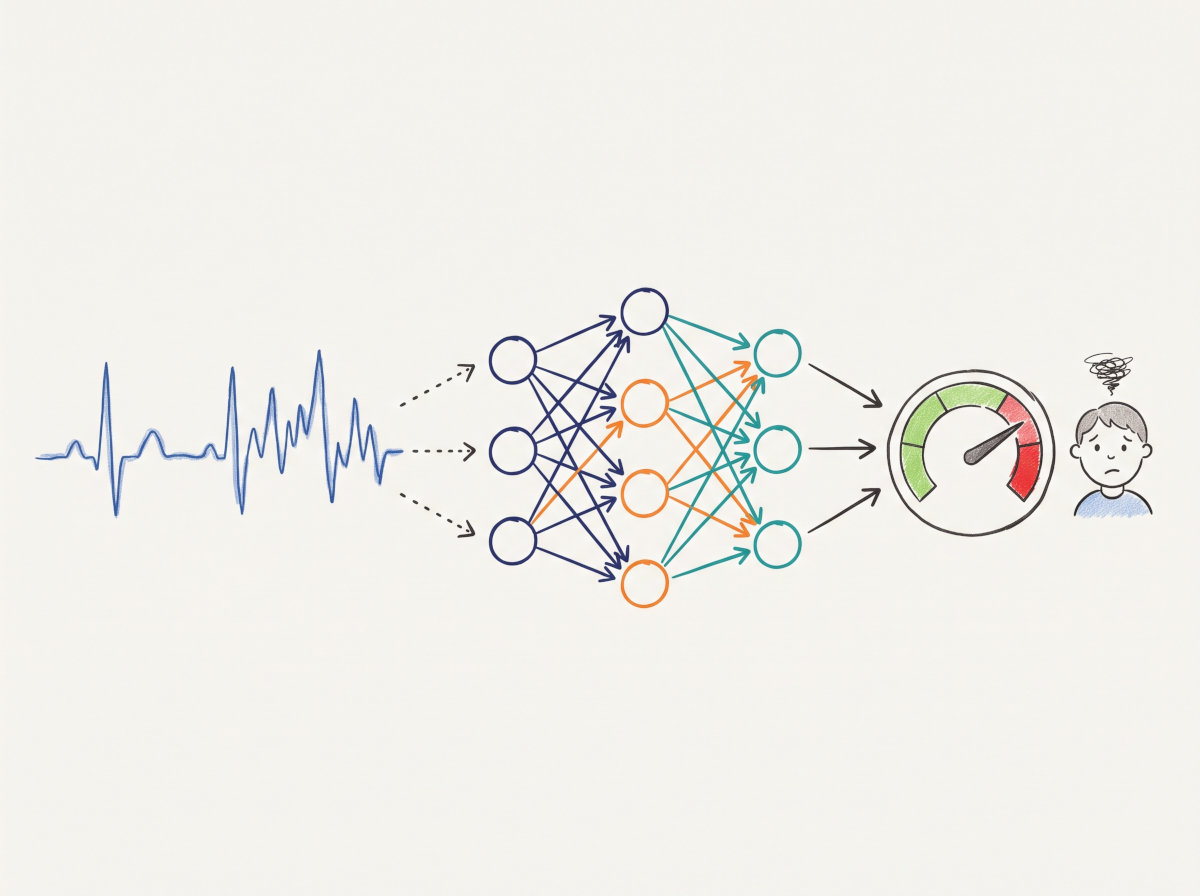
Stress Detection using biosignals

  • TU Delft
  • Curriculum project
  • Processed raw ECG, EDA and EMG data using SciPy, designing Butterworth filters and wavelet analysis to remove noise and extract meaningful features like heart rate variability and perspiration
  • Trained and validated SVMs, neural networks and random forest classifiers, using Principal Component Analysis for dimensionality reduction and feature selection
  • Evaluated performance using confusion matrices and mean balanced accuracy to identify class imbalances
Image: Gemini Hydrogen

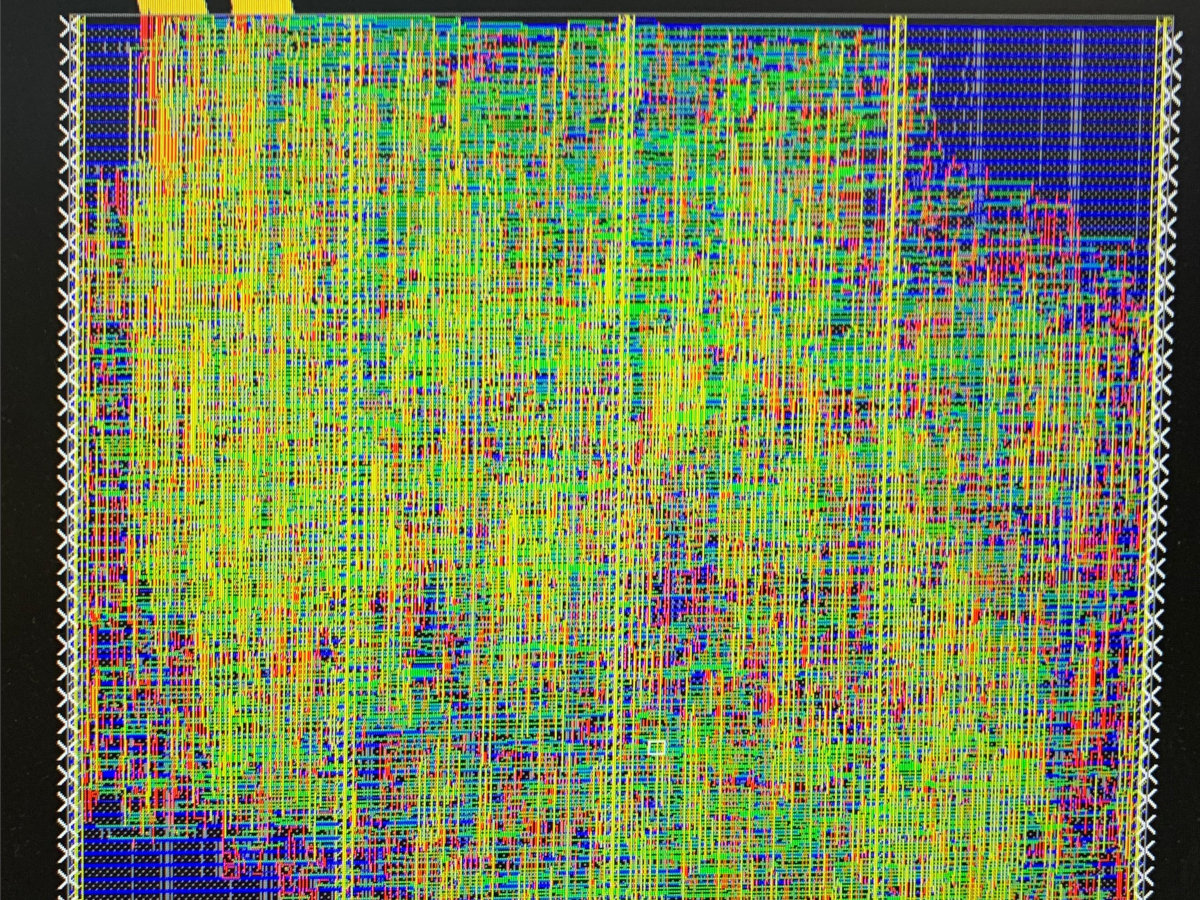
Designing a chip

  • TU Delft
  • Curriculum project
  • Designed a DOOM-inspired game on a chip
  • Implemented and optimised complex Finite State Machines in VHDL to fit on a small chip area
  • Designed trigonometric function approximations using boolean logic

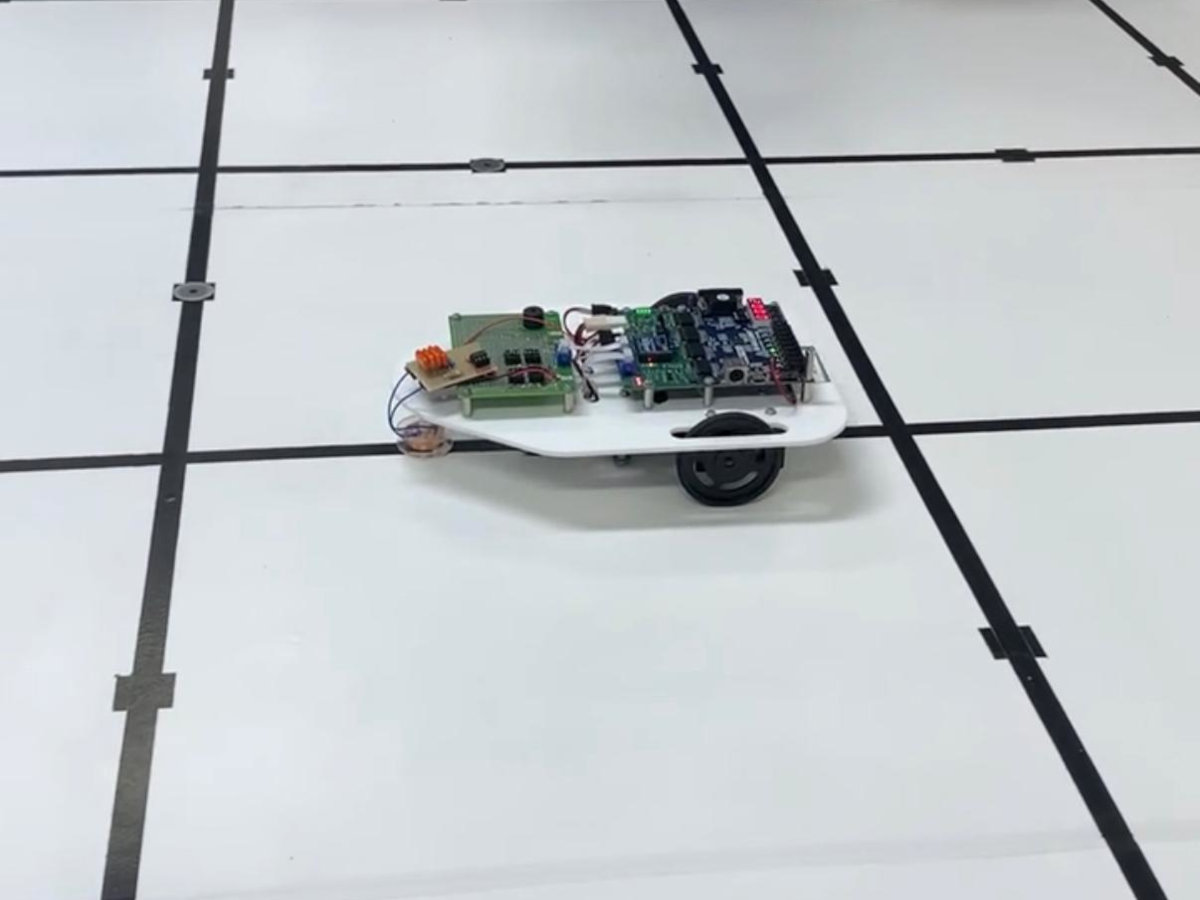
Navigating a maze while avoiding mines

  • TU Delft
  • Curriculum project
  • Designed metal (mine) detectors using inductive sensor LC circuitry with operational amplifiers
  • Implemented advanced finite state machines on FPGAs using VHDL
  • Designed and Optimised maze solver and routing algorithms in C

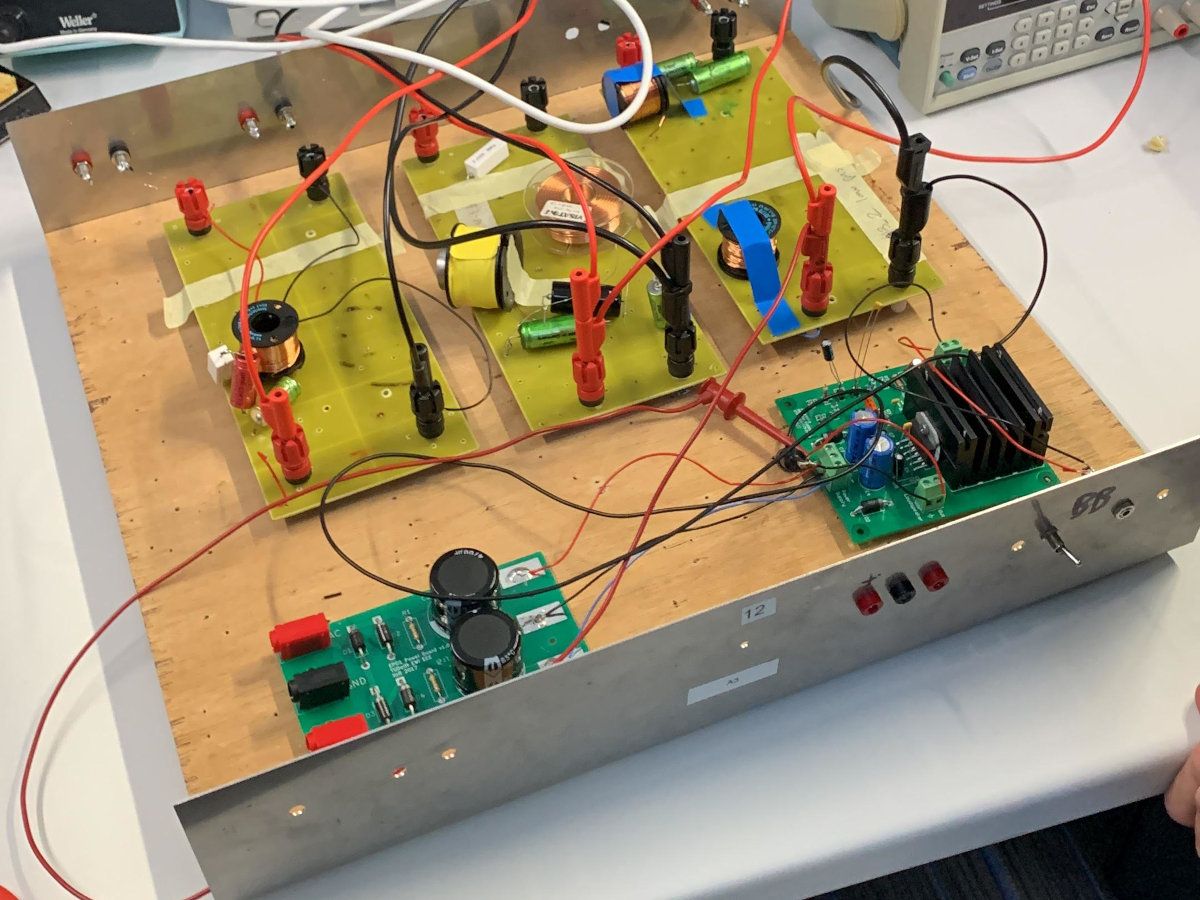
Speaker amplifier design

  • TU Delft
  • Curriculum project
  • Modelled speaker electrodynamics and passive electrical filters using linear ordinary differential equations to effectively split audio signals into their bass, mid, and tweeter components
  • Simulated models using AC Sweep analysis in LT-Spice to optimise for a flat frequency response
  • Fabricated the amplifier and validated performance by measuring the real-world Bode plot response